Accedi per continuare — completeremo l’operazione per te. Non hai un account? Registrati
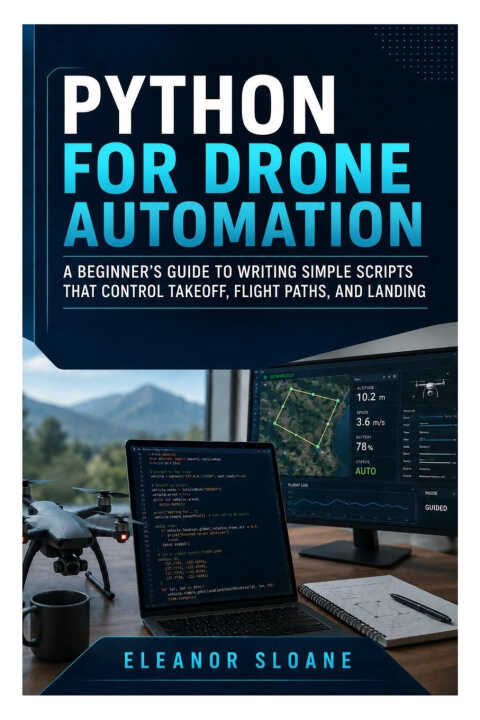
Python for Drone Automation
Descrizione in inglese
Write Safer Flight Scripts and Turn Simple Commands into Complete Drone MissionsA basic program can tell a drone to take off, move, and land. A reliable program must do much more.It must verify the connection, check the battery, validate the route, monitor telemetry, distinguish command acceptance from task completion, handle communication failures, preserve a landing path, record what happened, and prevent invalid instructions from reaching the aircraft.Python for Drone Automation is a beginner-friendly guide to writing scripts that control takeoff, flight paths, image capture, waypoint missions, and landing.The book teaches supervised automation. Python directs the mission sequence while the drone's onboard flight controller continues handling balance, sensor processing, motor control, and built-in safety behaviour. The operator remains responsible for preparing the aircraft, approving each test, observing the flight, and intervening when necessary.Inside this practical guide, you will learn how to:Understand how a script communicates with a flight controllerSeparate high-level commands from low-level motor controlDistinguish manual, assisted, and automated flightModel a complete mission as a sequence of controlled statesUnderstand commands, responses, telemetry, events, and acknowledgementsRecognise the difference between command acceptance and completed movementCompare open-loop movement with feedback-based automationWork safely with local and global coordinate systemsDefine operating limits, emergency actions, and abort conditionsCreate a basic flight-risk assessmentInspect the aircraft, battery, propellers, connection, and test areaThe first learning track uses a small indoor platform to teach connection handling, bounded movement, telemetry, video capture, protected cleanup, and physical-flight supervision. The second track uses PX4 Software-in-the-Loop, Gazebo, QGroundControl, and MAVSDK-Python to teach global waypoint missions without requiring a physical PX4 aircraft.Supporting resources include Tello and MAVSDK-Python command references, unit tables, installation and troubleshooting guidance, indoor preflight and post-flight checklists, a PX4 simulation checklist, an automated-mission review checklist, emergency procedures, and a software-version record.Whether you are new to Python, learning drone programming, teaching a supervised workshop, building robotics projects, or preparing for more advanced PX4 and MAVLink development, this book provides a structured path from offline route validation to controlled indoor flight and simulated GPS missions.Validate the route. Preview the commands. Monitor the aircraft. Protect the landing path. Treat every connection and sensor value as something that can fail.
▾ Leggi tutto▴ Riduci
Disponibile per scambio
0Nessuno propone questo scambio al momento.
Avvisami quando disponibileRecensioni
Bu kitaba henüz yorum yapılmamış. İlk yorumu sen yaz.